Gopikrishnan Nair
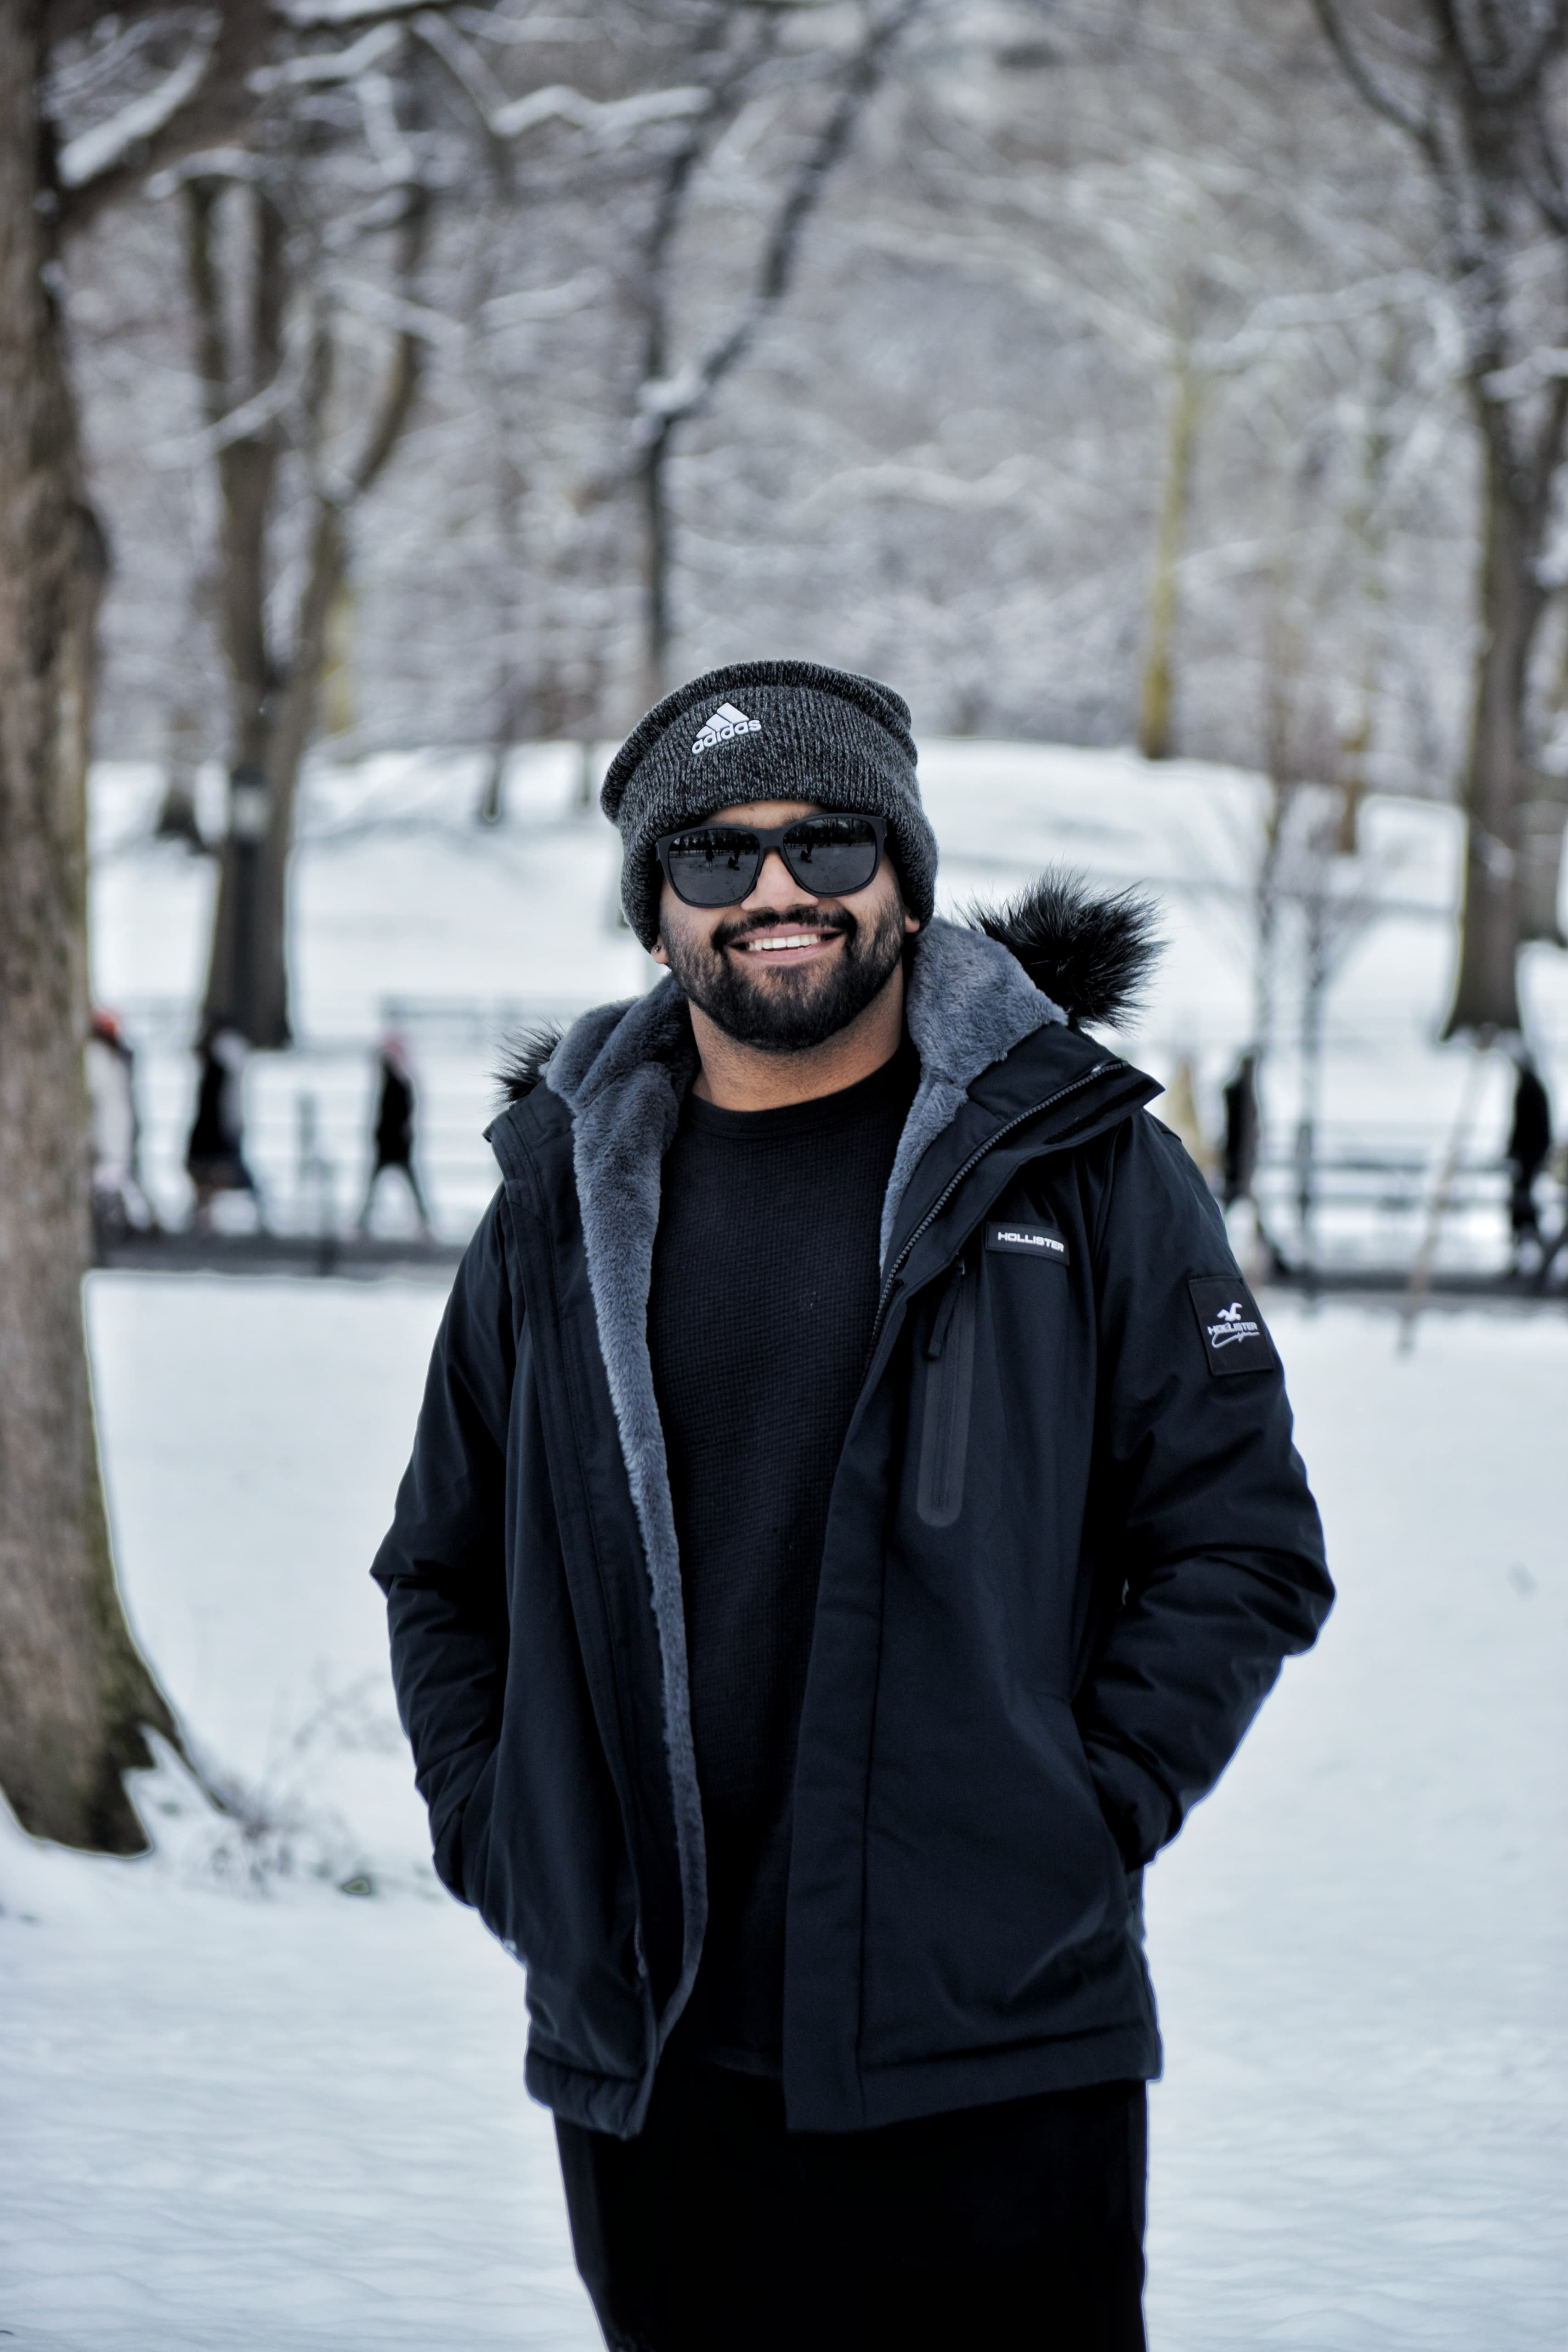
Name: Gopikrishnan Nair
Email: gopik.nair@nyu.edu
Phone: (714) 902-7650
About me
I am a Mechatronics and Robotics Systems Engineer with a strong foundation in Robotics, Testing, ROS2 and Mechanical Design.
I thrive in cross-functional collaboration, having worked with electrical and software teams to integrate mechanical, electronic, and firmware components into complete systems. My background in curriculum development has strengthened my ability to communicate technical concepts clearly and work effectively in team environments.
Outside of engineering, I enjoy photography and gaming, and I'm fascinated by animals and wildlife. I'm always on the lookout for emerging technologies and love exploring how new innovations can be applied to solve real-world problems.
I am passionate about leveraging my skills to develop innovative solutions that address complex challenges in robotics and automation. I am eager to contribute my expertise to dynamic teams and projects that push the boundaries of technology.
My Journey
Experience
Mechatronics Engineer
Sweet Robo LLC
June 2025 - September 2025
- Led mechanical design of automated vending machines using SolidWorks and Fusion 360, developing modular CAD models to streamline assembly and maintenance
- Sourced critical components and managed vendor relationships to ensure cost-effective solutions and on-time delivery while maintaining quality standards
- Collaborated with electrical and software teams to integrate mechanical systems with electronics, firmware, and embedded controls, ensuring seamless system operation
- Utilized ANSYS for FEA simulation to optimize structural components and validate design decisions prior to prototyping
- Conducted comprehensive system testing and validation protocols, identifying design improvements and ensuring product reliability met performance specifications
Assistant Research Scientist
NYU Mechanical and Controls Lab
July 2024 - June 2025
- Designed hands-on experiments demonstrating mechanics, robotics, and control systems concepts using MATLAB/Simulink for simulation and analysis
- Integrated cutting-edge technologies including Fusion 360 for CAD modeling, MATLAB for control system simulation, Arduino and Raspberry Pi for IoT applications, and LabVIEW for data acquisition
- Developed comprehensive course materials including lecture notes, lab manuals, and multimedia presentations incorporating software tutorials and practical applications
- Collaborated with faculty and industry experts to align curriculum with industry-standard tools and emerging trends in mechatronics and automation
- Created evaluation tools and assessments to measure student understanding of both theoretical concepts and software proficiency
Mechanical Engineer
Subzero Motorsports
Jan 2021 - July 2021
- Vehicle Performance: Enhanced vehicle performance using MaxxECU software, gaining a competitive advantage in races.
- Lab Experiment Development: Design and implement hands-on lab experiments that demonstrate key concepts in mechanics, robotics, and control systems, ensuring alignment with educational objectives.
- Integration of Technologies: Incorporate the latest technologies and tools into course content to enhance learning experiences, such as CAD software, simulation tools, and IoT devices.
- Collaboration: Work closely with faculty members and industry experts to align course content with industry standards and emerging trends in mechanical and control systems.
- Evaluation and Assessment: Develop evaluation tools and assessments to measure student understanding and engagement, providing feedback and support for continuous improvement.
Mechanical Engineer Intern
Sumadhura Infracon Pvt. Ltd.
Jun 2019 - July 2019
- Analyzed Building Plans: Evaluated architectural plans for three building complexes to establish foundational project knowledge.
- Collaborated with MEP Engineers: Worked with Mechanical, Electrical, and Plumbing engineers to develop project plans using AutoCAD.
- Designed Utility Plans: Created AutoCAD utility plans for the largest building complex.
Education
New York University
MS in Mechatronics, Robotics & Automation
2022 - 2024 | GPA: 3.67/4.0
Focus: ROS2, Advanced Mechatronics,Robotics, Embedded Systems, Computer Vision
Birla Institute Technology and Science
B.E in Mechanical Engineering
2017 - 2021
Focus: CAD Design, FEA Simulation (ANSYS), Manufacturing Processes
Indian School Muscat
2003 - 2017
Projects
- All
- Robotics
- Computer Vision
- Other

Basic Augmented Reality using Python
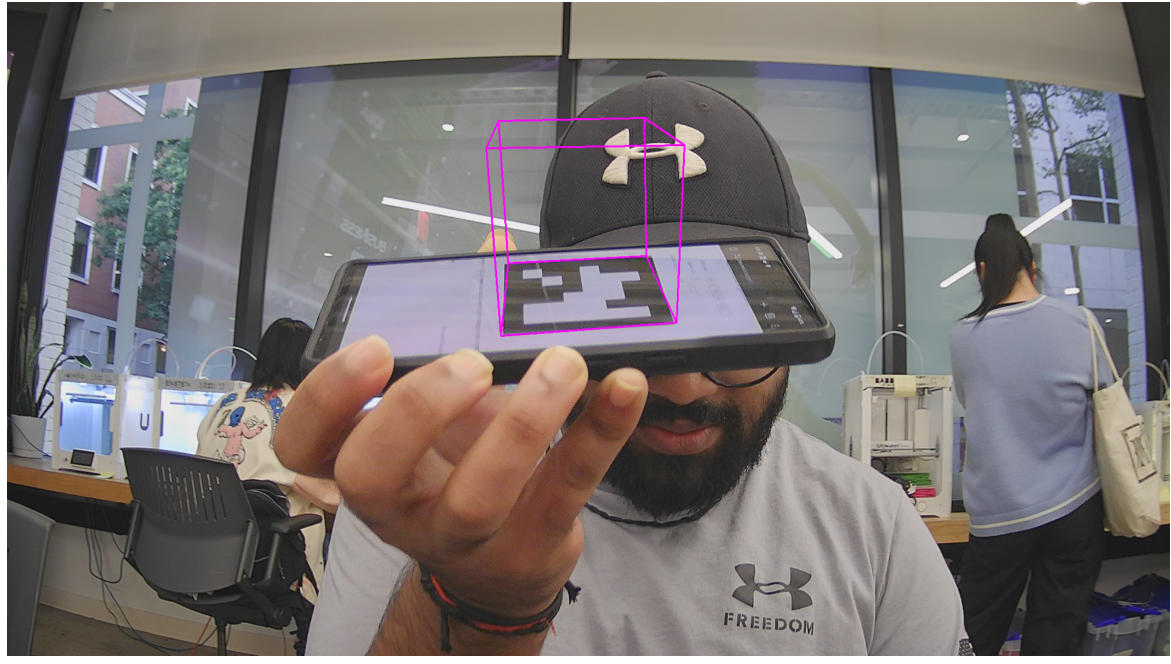
This project uses ArUco markers to create a simple augmented reality (AR) experience. ArUco markers, developed in 2014, are binary fiducial markers that help accurately integrate virtual objects with the real world. By employing OpenCV and Numpy libraries, the project combines real and virtual elements in real-time, enhancing interactive experiences through visual and spatial alignment.

Autonomous AGV Navigation System
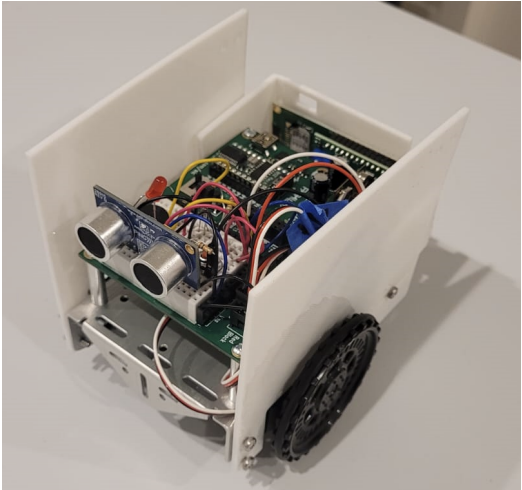
Designed an automated guided vehicle (AGV) that autonomously navigates a factory floor, efficiently transporting widgets between processing stations. The system follows predefined lanes, avoids obstacles, and dynamically adapts to pickup and drop-off conditions using the Parallax Propeller.
Camera Calibration
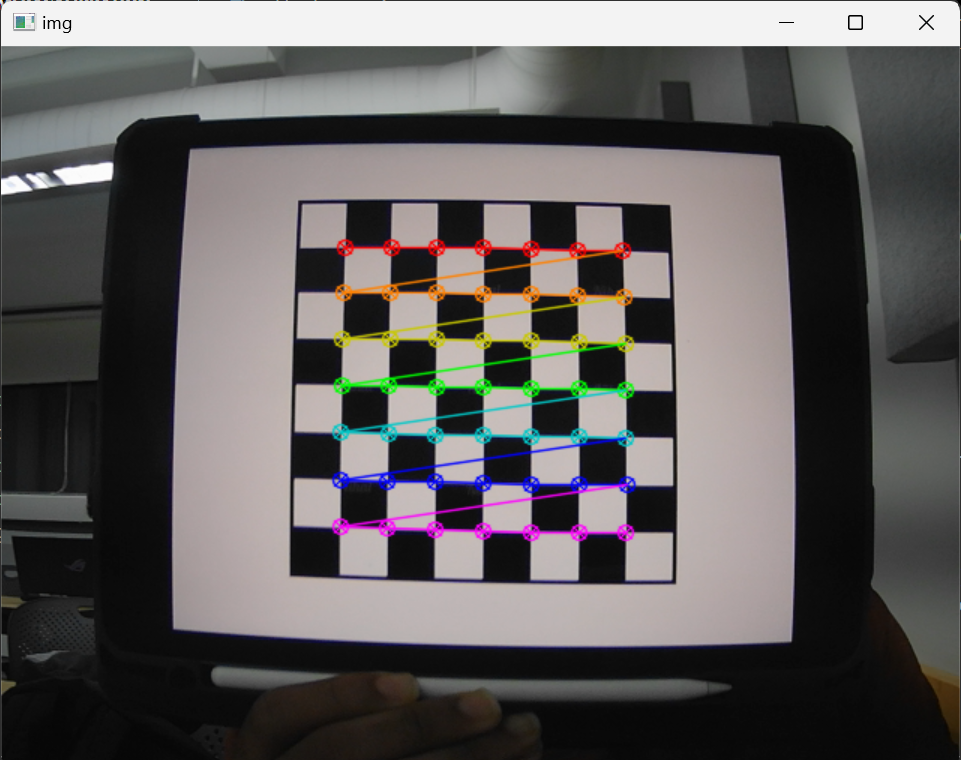
This Python script performs camera calibration using OpenCV by detecting a checkerboard pattern in a series of images. The calibration process determines the camera matrix (K) and distortion coefficients, which are essential for correcting lens distortion in computer vision applications.


IoT Pedometer System with MQTT & Real-Time Dashboard
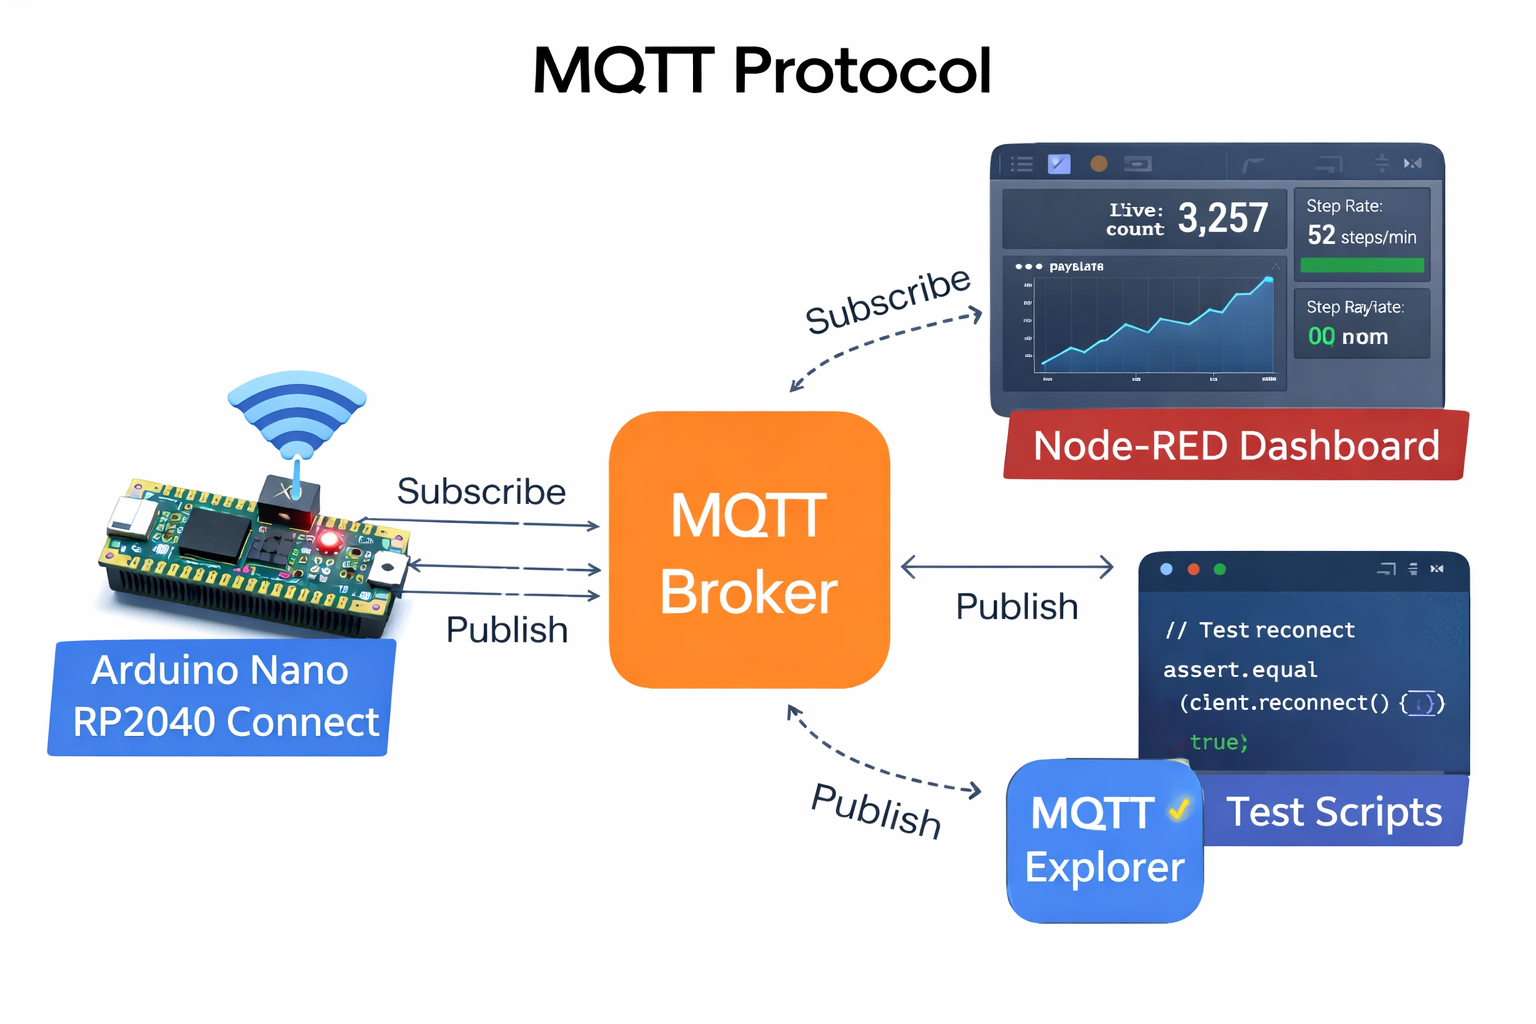
Developed an IoT-based pedometer using Arduino Nano RP2040 Connect with onboard IMU, implementing secure MQTT communication (TLS) to publish real-time step data to a Node-RED dashboard. Performed comprehensive testing using MQTT Explorer to validate payload structure, QoS behavior, and message retention. Designed QA test cases covering connectivity loss, reconnection handling, and fault conditions to ensure reliable message delivery.
Contact
Address
Sunnyvale CA 94085
Call Me
+1 714 902 7650